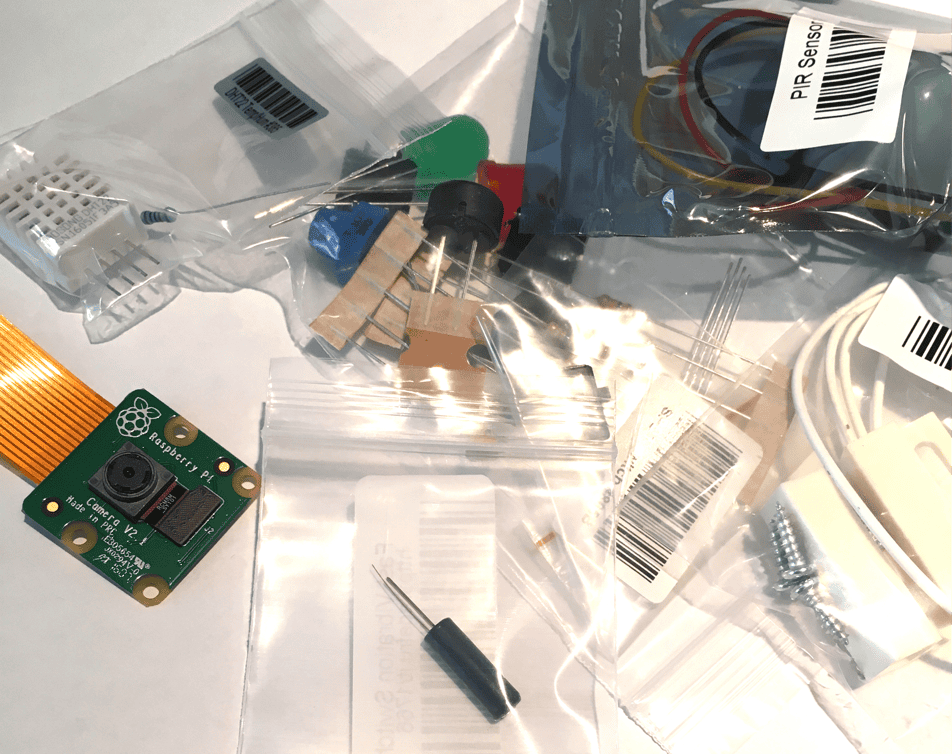
To make your robot seem smart, and at the very least not damage itself by colliding with obstacles, it needs sensors.
Sensors allow your robot to read its environment. We are talking light/colour, sound, distance, and so on. For very intelligent robots you will want computer vision where, using a webcam, it can actually make sense of what it is “seeing”.
If we broaden our definition to “taking input” then of course we can also consider other types of input such as infrared, bluetooth, radio, and wifi.
Most of us would start with the basics, so we would look at avoiding obstacles and following lines, before moving on to building the next Terminator 😉